ENCY has introduced a series of updates to its ENCY Hyper visual programming platform for industrial robots, including browser-based access that allows users to explore the software without installing it on their computers.CENCY Hyper enables engineers and operators to design robotic work cells, develop programmes, test operations through simulation and connect directly to physical robots for execution and adjustments on the shop floor. The latest updates aim to simplify robot programming, improve path teaching and provide greater control over industrial processes such as welding, adhesive dispensing and polishing.
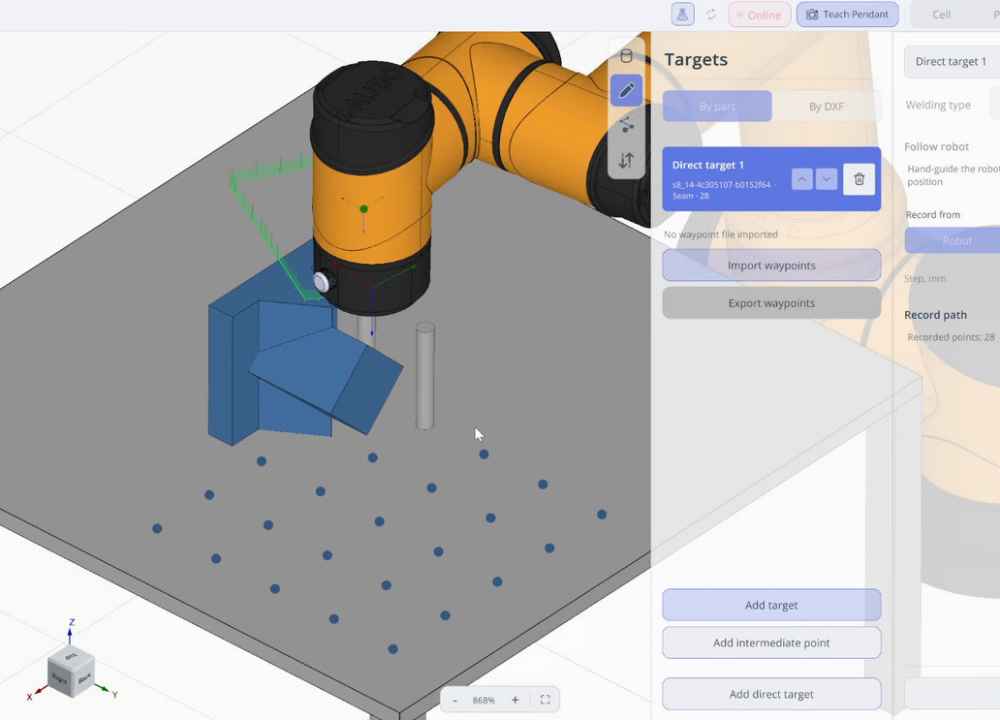
One of the key additions is the ability to teach robot paths directly from the workpiece. This feature allows operators to record the actual position of the robot while carrying out a task. Using a teach pendant or manually guiding the robot arm, users can add waypoints along a joint, contour or surface.
For longer welding seams and similar applications, the Record Path function allows operators to trace the required route in a continuous movement. The software automatically records points at fixed distance intervals as the tool moves along the selected path. This reduces the need to enter individual coordinates manually.
The platform also supports a connected 3D pointer, allowing users to capture individual points or transfer coordinates directly from a workpiece without moving the robot. Recorded points can be saved and reused in other commands. For example, the same path can be applied to adhesive dispensing when it follows an existing welding route, avoiding the need to programme the movement again.
ENCY Hyper has also introduced an improved Polishing command to give users greater control over surface-finishing operations. Operators can adjust tool angles, contact settings, polishing width and the number of passes. The software supports zigzag and circular polishing patterns and allows additional passes to be added without teaching the complete path again.
These functions are designed to help manufacturers manage different surface-finishing requirements while reducing programming time and simplifying adjustments. The latest release also includes improvements to robot movement and software navigation. An updated ESTUN driver provides smoother robot movement when operators use the jogging controls through the Hyper pendant interface. The improvements have been tested on a physical robot.
The 3D viewing environment has also been updated. Zooming now focuses on the point beneath the cursor, making it easier to move between an overall view of the robotic work cell and specific areas requiring inspection. Camera movement also stops immediately when the user stops operating the controls.
Other interface improvements include a unified window header, a Home button, a simpler project-starting process and revised display settings. The updates are intended to make robot programming and operation easier for engineers and shop-floor personnel while providing additional flexibility for industrial automation projects. ENCY Hyper combines programming, simulation and physical robot operation within a single working environment. The new browser-based access gives users an opportunity to explore its capabilities before installing the software.